Hi! I'm Alexis, a Robotics Engineering student pursuing a double degree between EPFL and École Centrale de Nantes.

I'm interested in autonomous systems and control methods. Wether it's new approaches with Reinforcement Learning or traditional ones. I like to balance between the opportunities offered by simulation and implementing my ideas into real products.

You can find evidence of this balance on the project section with my experiences ranging from ROS2 control to RL agent training on multiple environments and engines.

Outside of robotics, I love to play sports. I started with , this early passion propagated to all racket sports! I'm also a volleyball player and half-marathon runner. Overall, I would say that playing sports is my favorite hobby!!

🏓 back when i was good

I'm actively seeking a 6-month industry internship in robotics starting September 2026. If you're working on legged robots, embodied AI, or autonomous systems, I'd love to connect! Feel free to reach out!

Musculoskeletal Table Tennis
Semester Project Feb – Jun 2026 · Mathis Lab · EPFL

Musculoskeletal Table Tennis

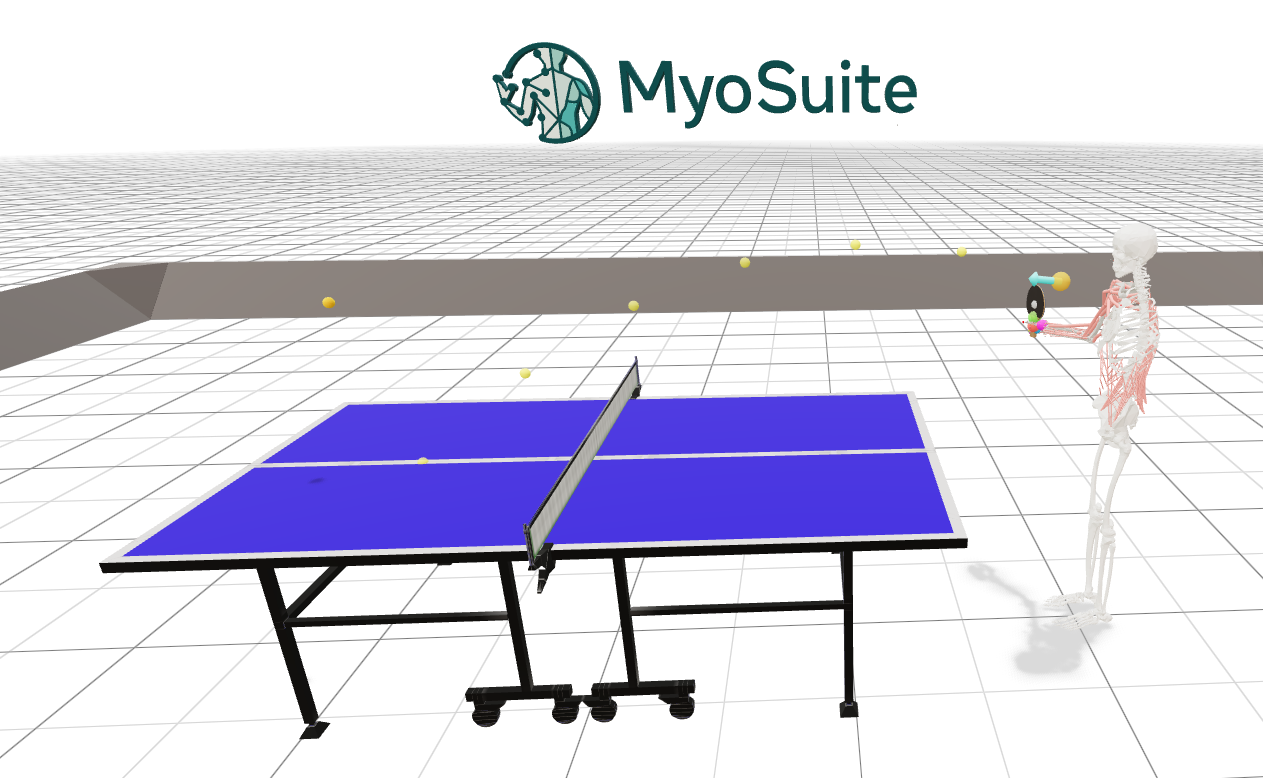
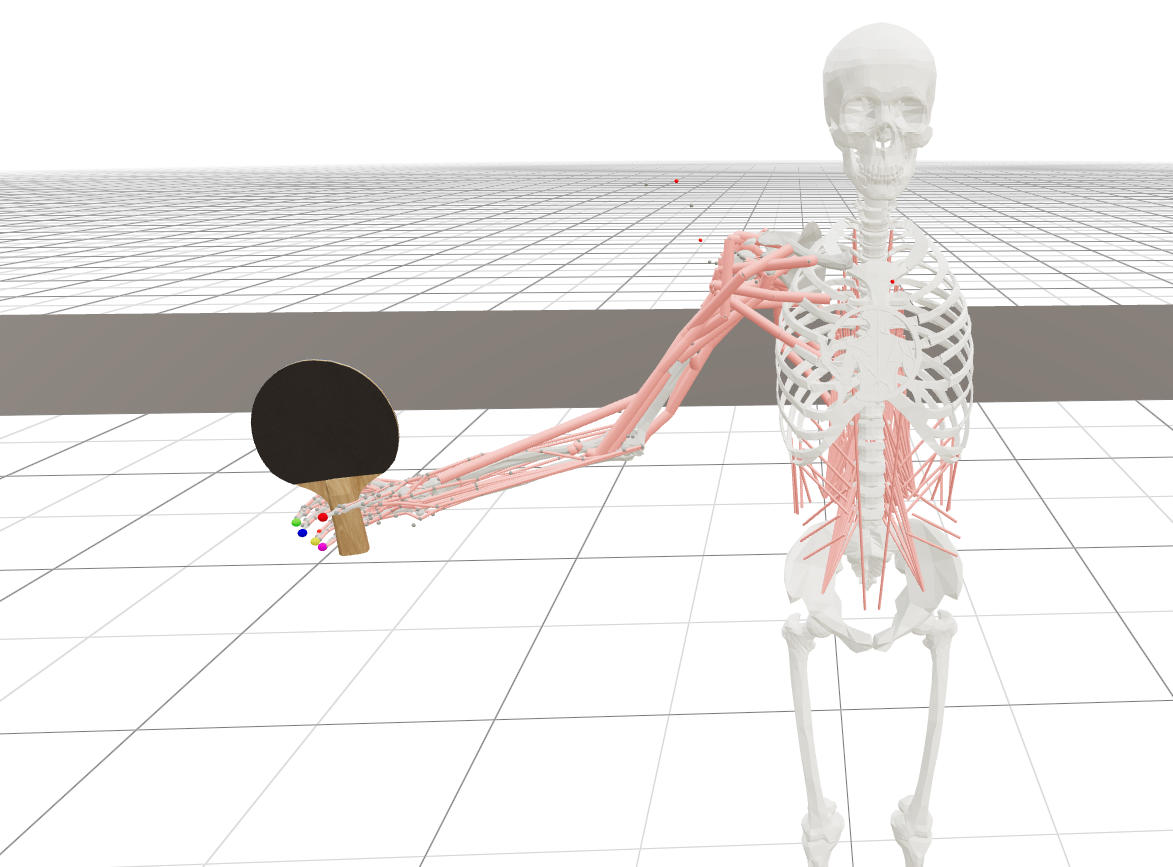
Semester project enhancing an RL agent to play table tennis using complex musculoskeletal models within the MyoSuite and MuJoCo frameworks. Developing an adaptable control policy capable of precise muscle coordination and rapid strategic decision-making.
Quadruped Locomotion
AI Team Feb – Jun 2026 · EPFL AI Team

Quadruped Locomotion

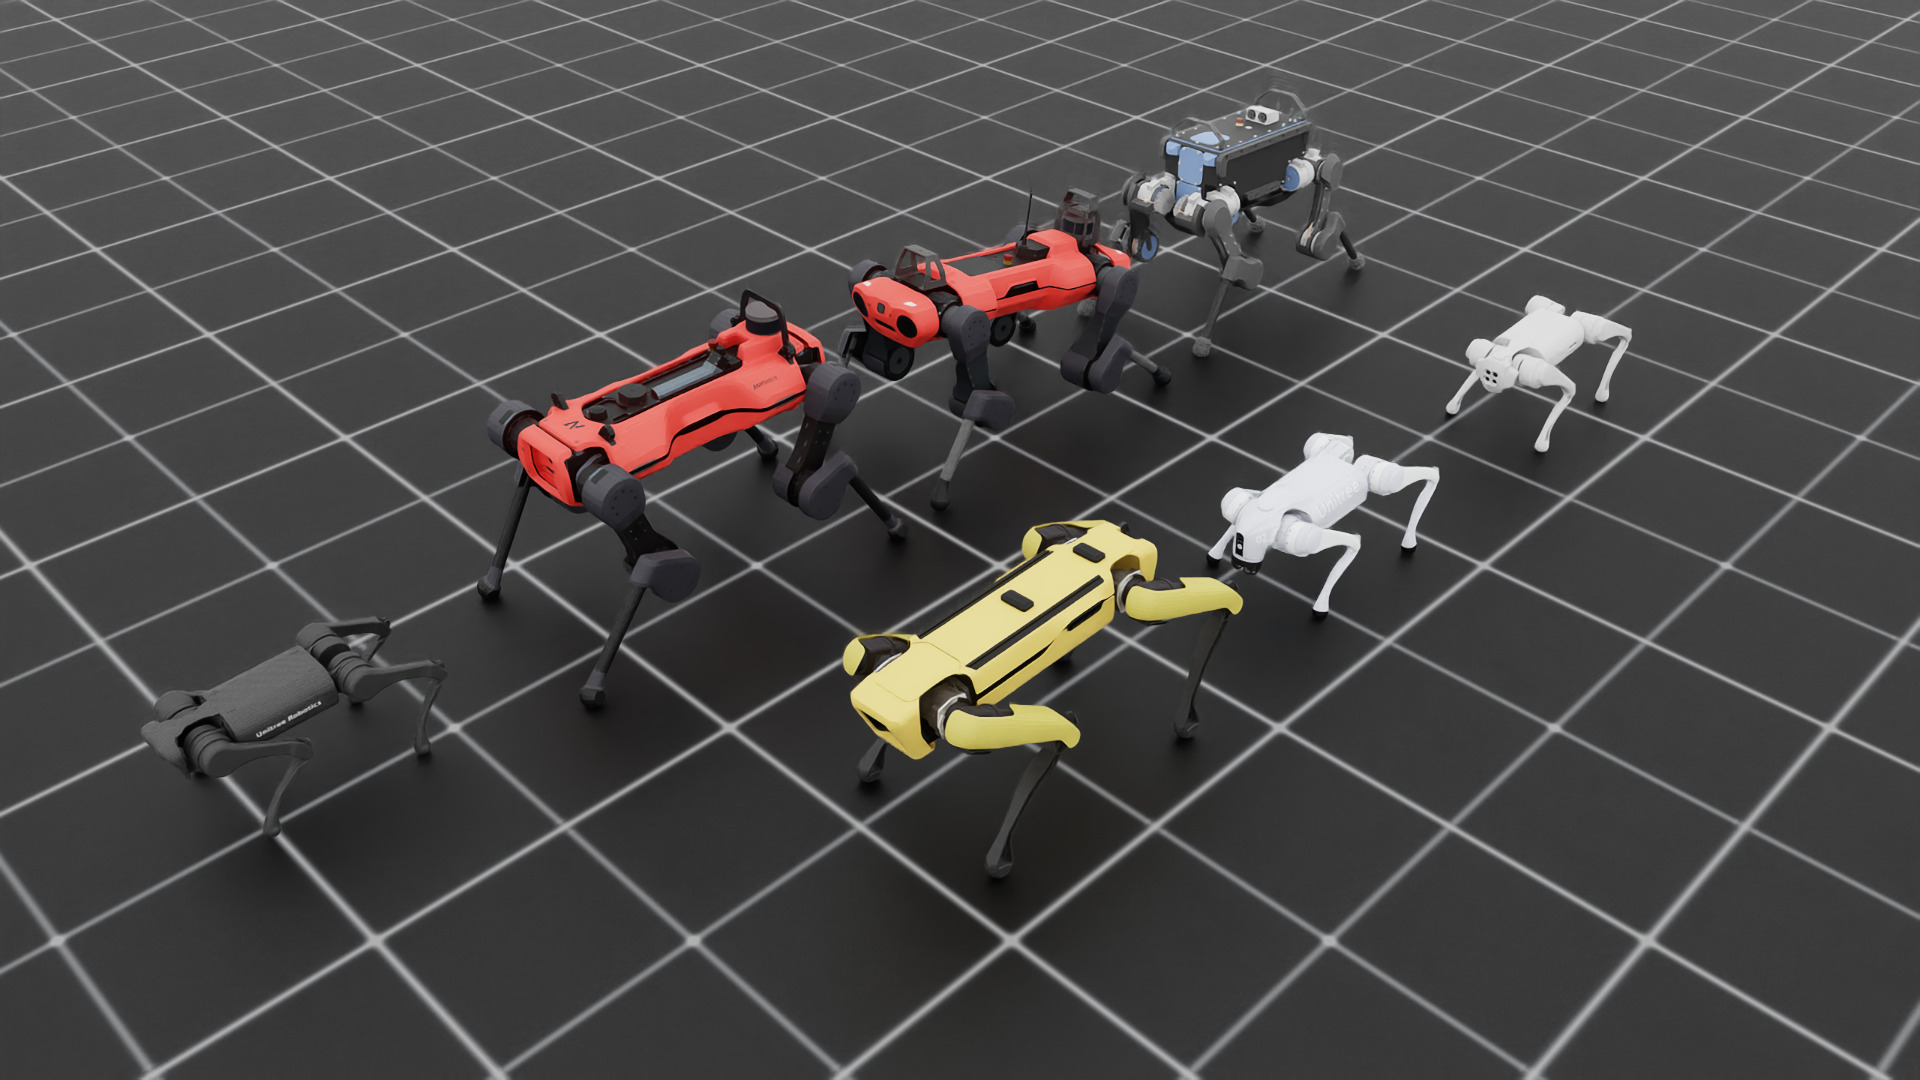
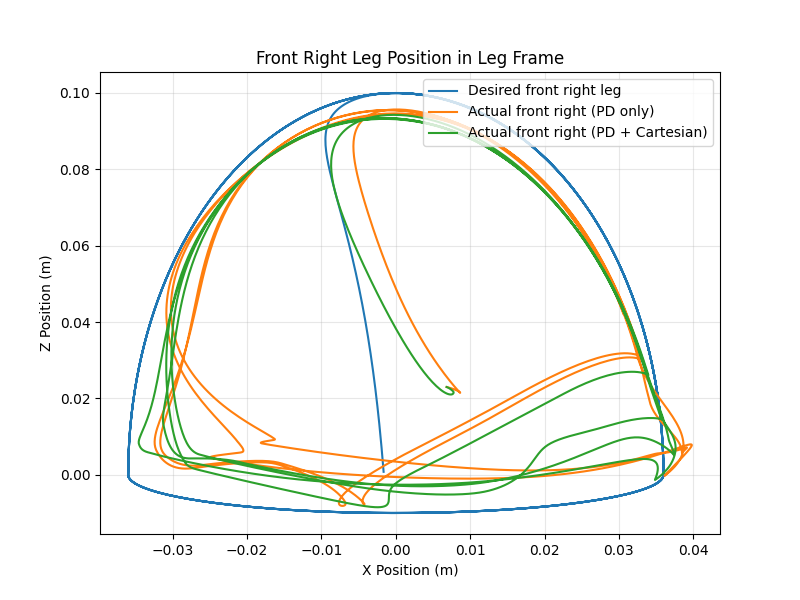
Developed quadruped locomotion policies with reinforcement learning using NVIDIA Isaac Lab. Worked on sim-to-sim and sim-to-real transfer to deploy the learned policy on the Unitree Go2 quadruped robot.

Robotic Guide Dog
Hackathon Apr 2026 · EPFL

Robotic Guide Dog

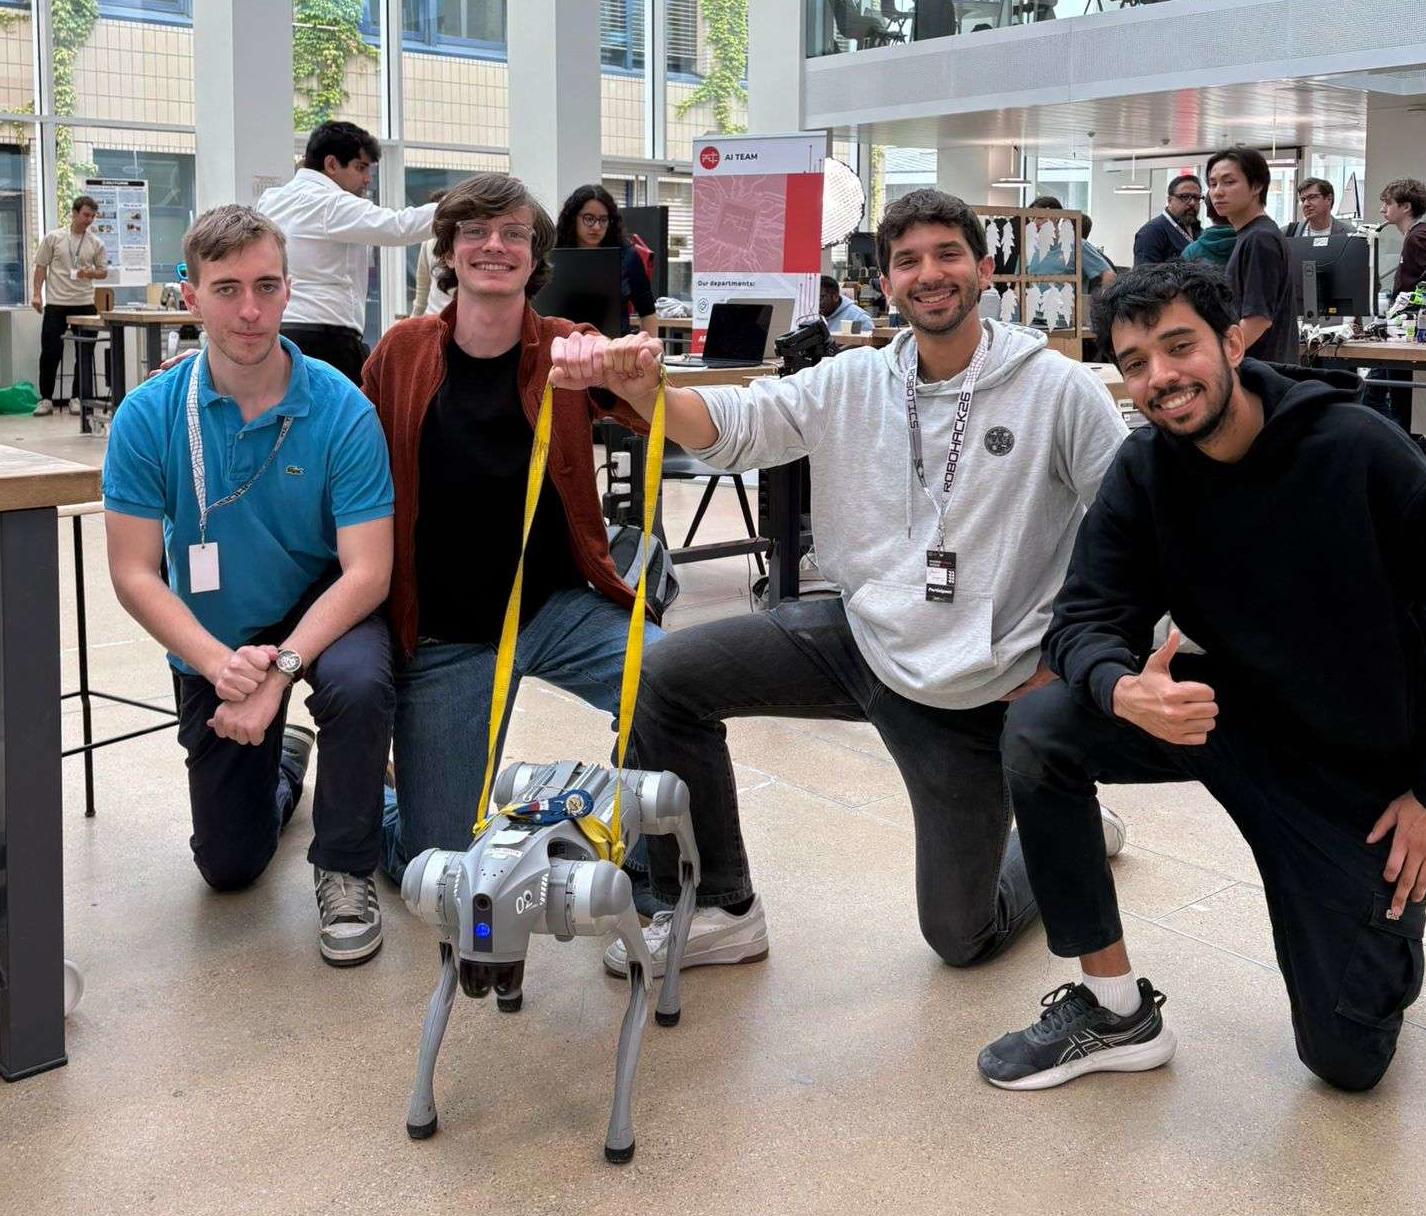
RoboHack2026 (EPFL) hackathon project: programmed a robotic guide dog (code-name Northern-Star) with GPS-based global navigation and agentic natural language interaction for real-time guidance. Implemented autonomous path planning and human interaction in a 36-hour challenge.

Rocket Landing with MPC
Course ME-425 Sep 2025 – Jan 2026 · EPFL

Rocket Landing with MPC

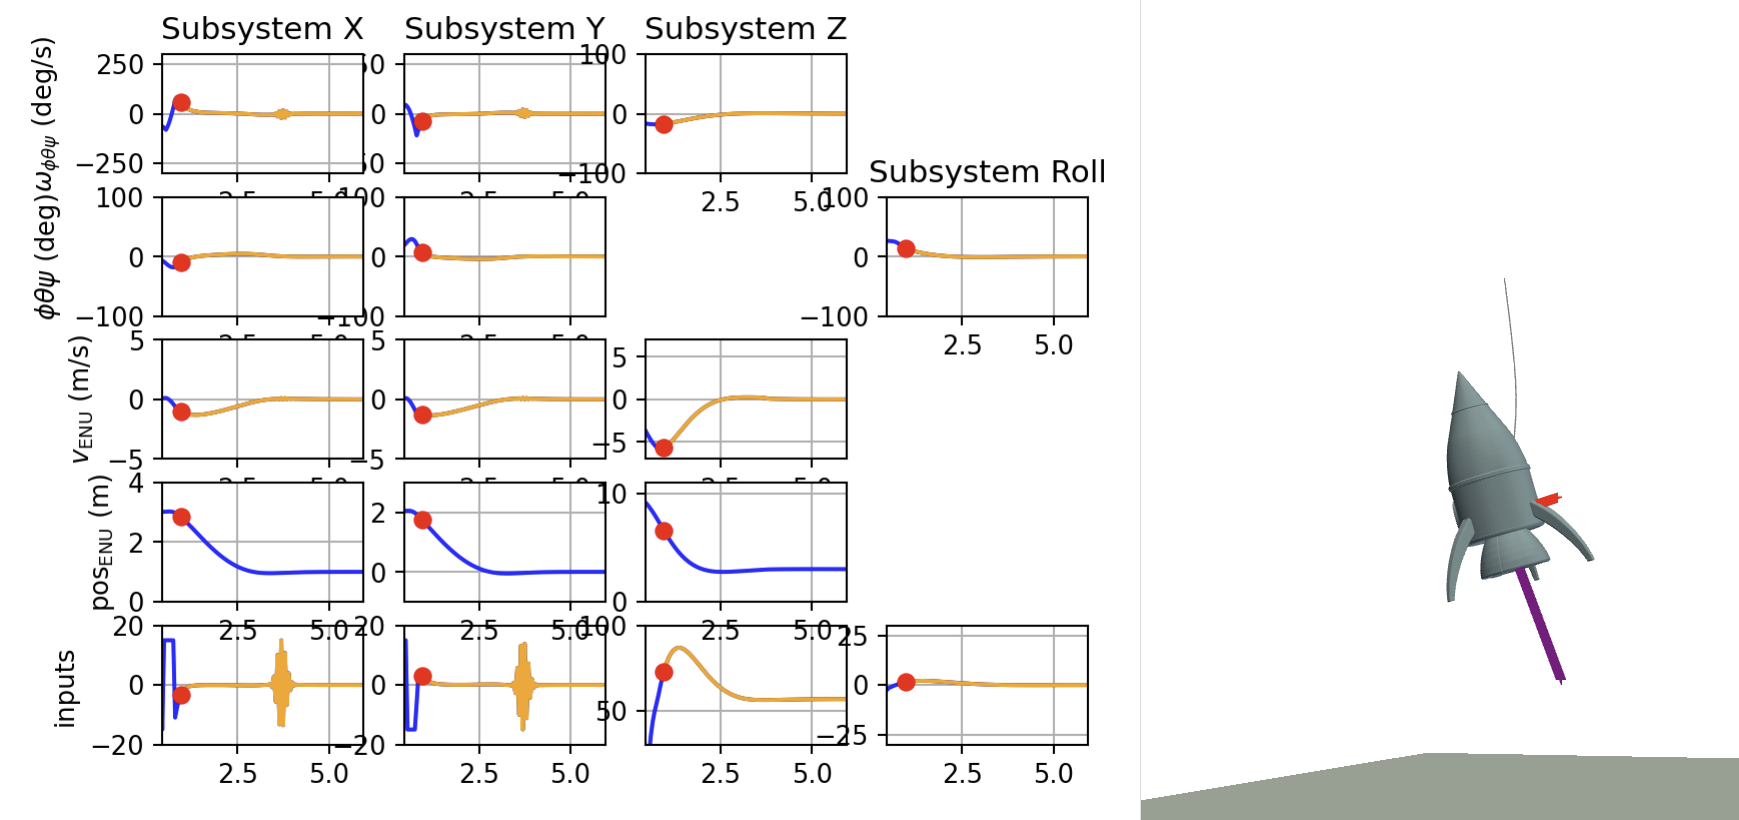
A control project demonstrating autonomous rocket landing using Robust and Nonlinear Model Predictive Control (MPC). Engineered a 12-state NMPC for propulsive landing and Robust Tube MPC for vertical descent to guarantee collision avoidance under stochastic disturbances.

Legged Robot — Quadruped Locomotion
Course MICRO-507 Sep 2025 – Jan 2026 · EPFL

Legged Robot — Quadruped Locomotion

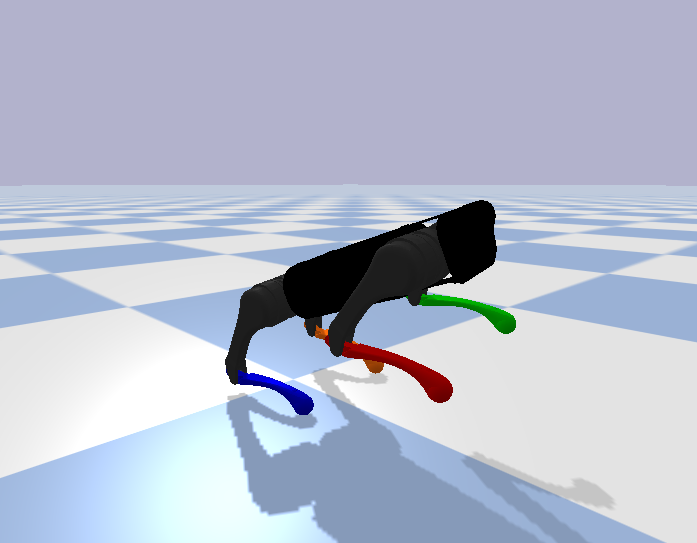
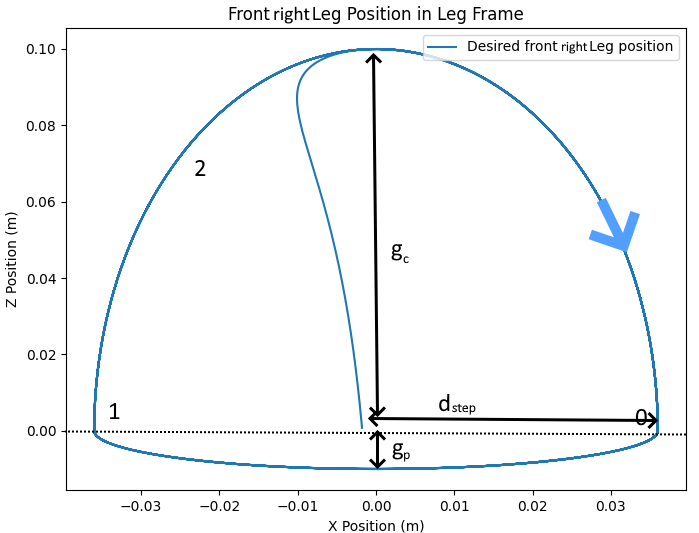
Explored two control approaches for quadruped locomotion on a Unitree A1 robot: gait synthesis with Central Pattern Generators (CPG) and deep reinforcement learning via DRL and CPG-RL algorithms. Simulations performed in a gym environment using Stable-Baselines3 and PyTorch.

6-DOF Robotic Platform Control
Internship Feb – Jun 2025 · ISIR · Sorbonne

6-DOF Robotic Platform Control

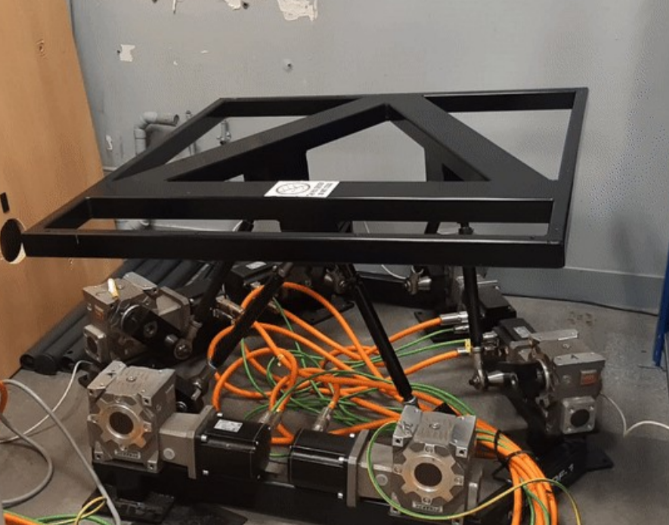
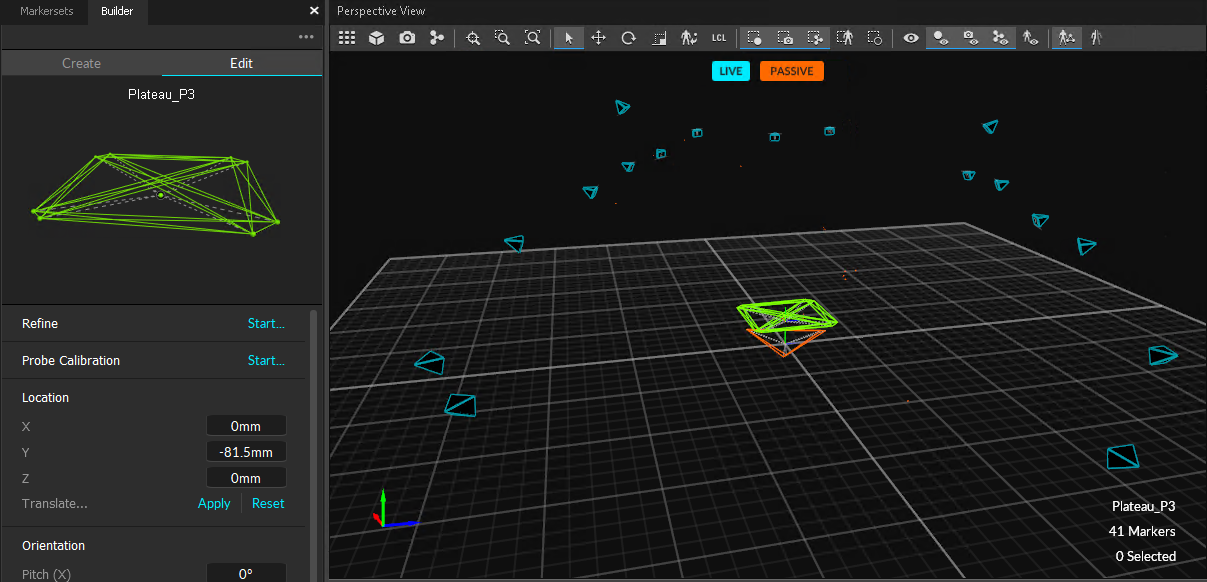
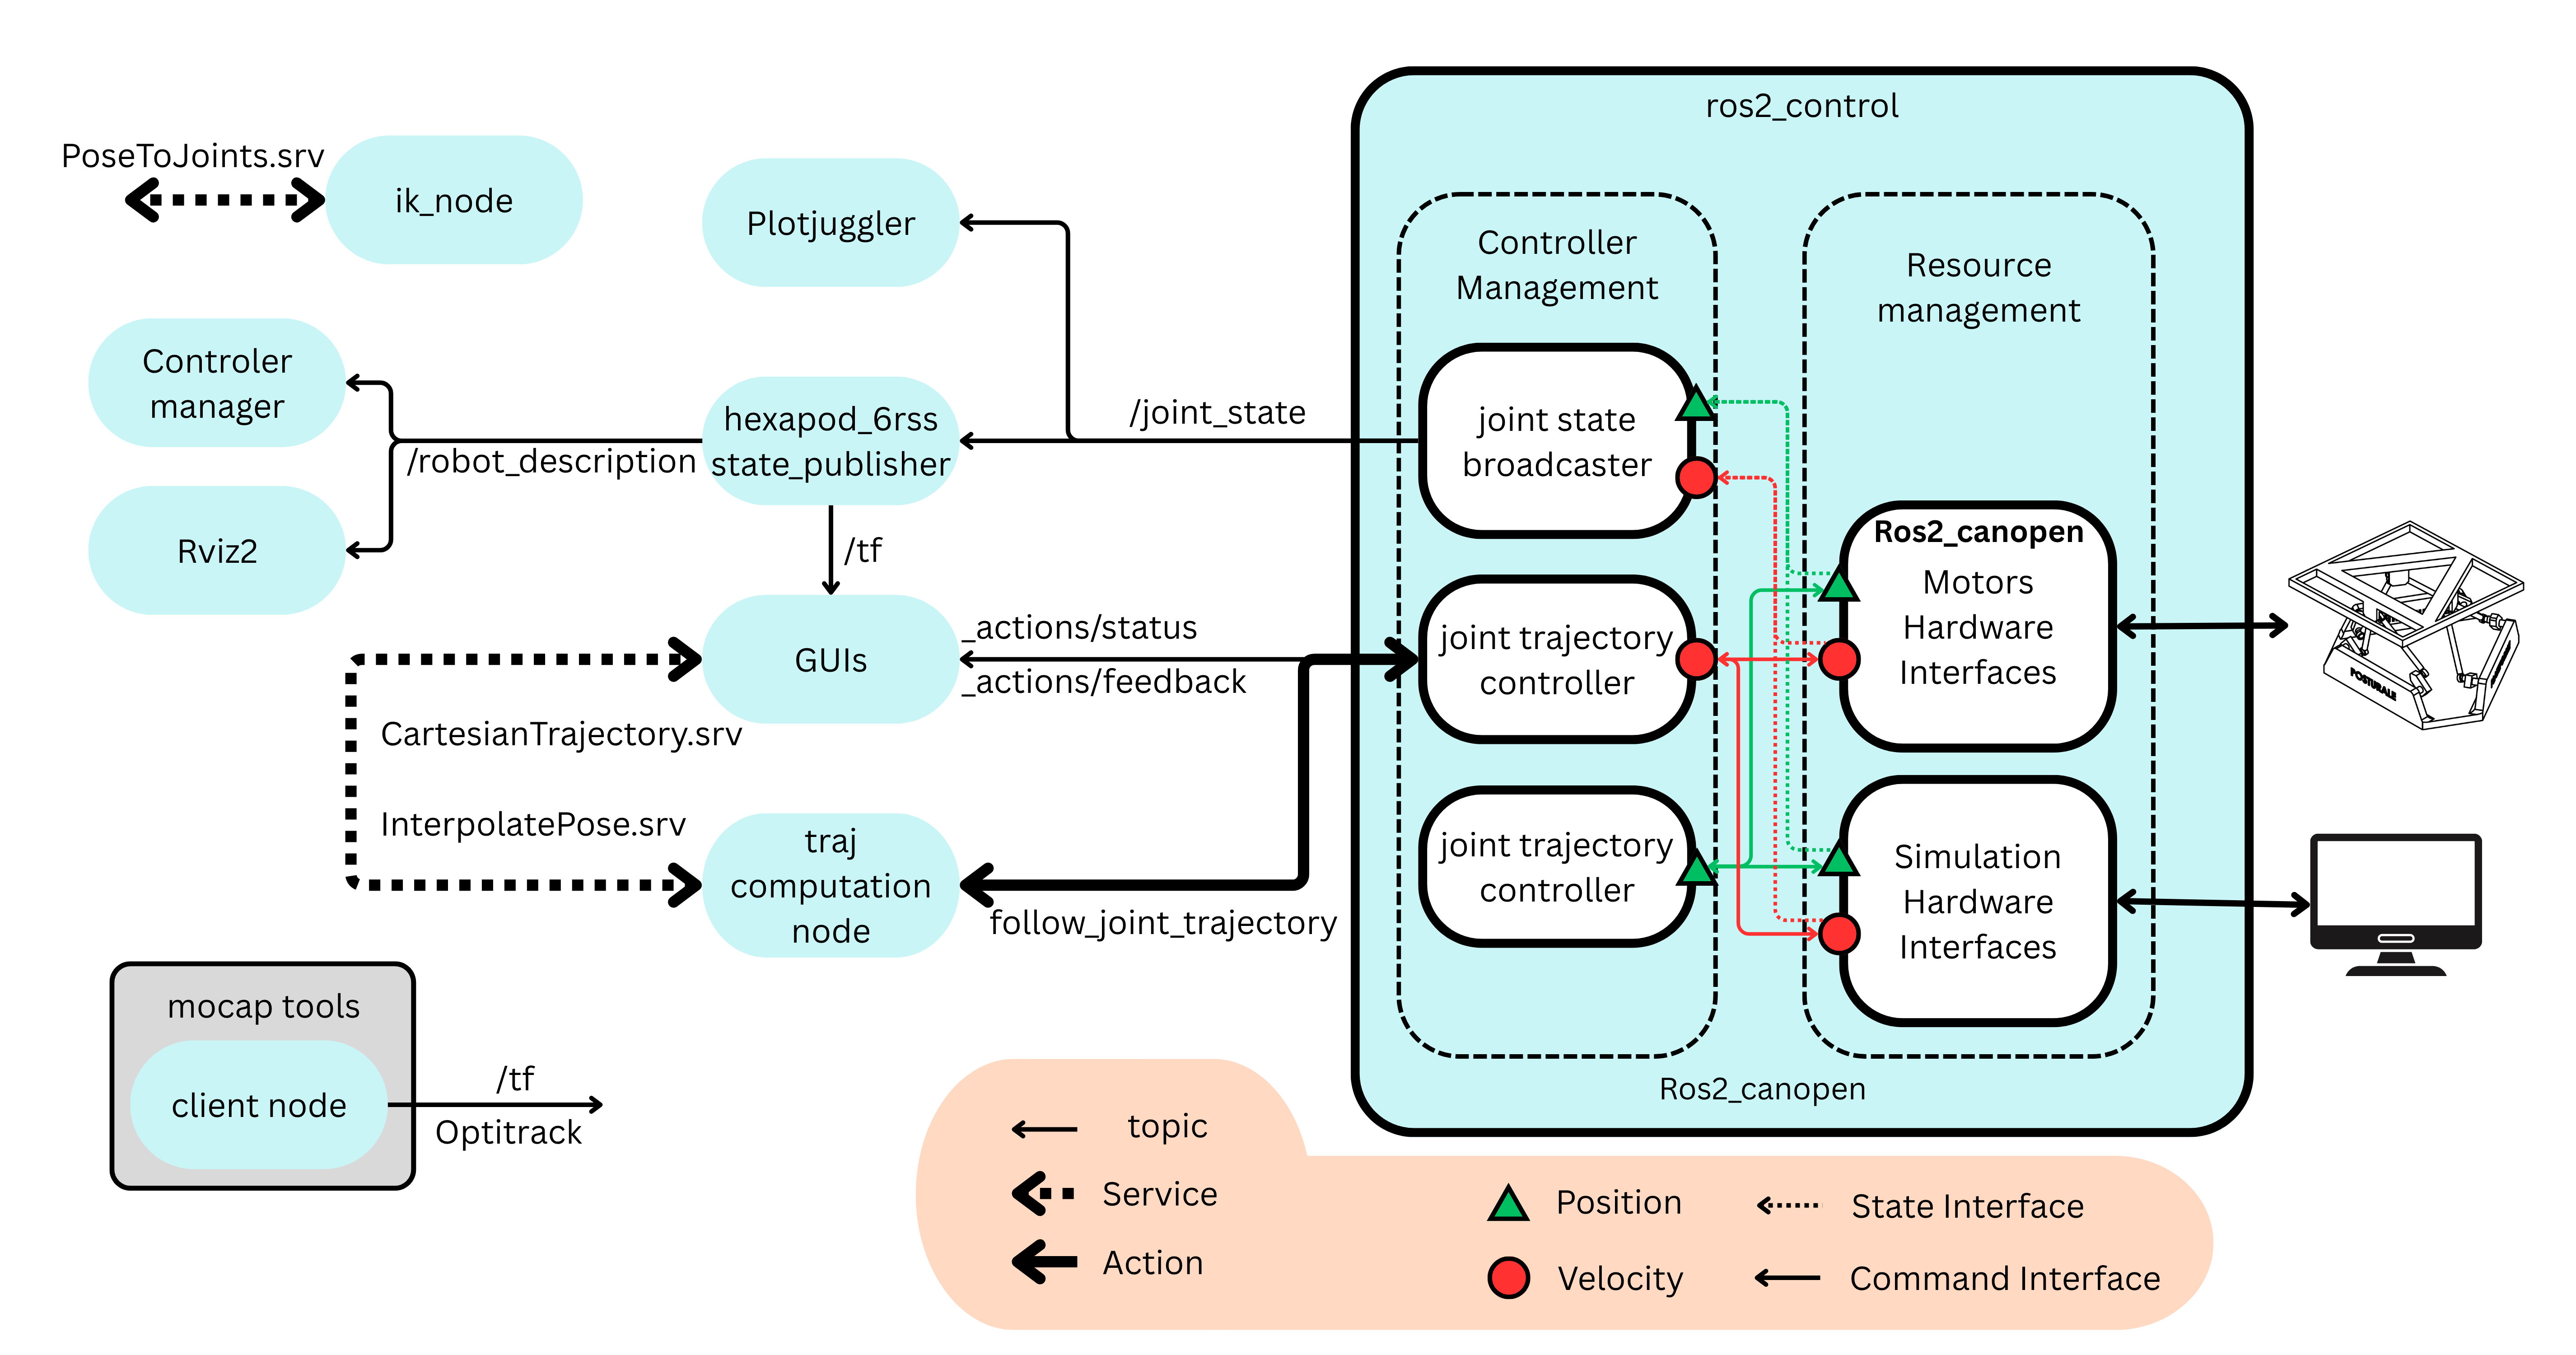
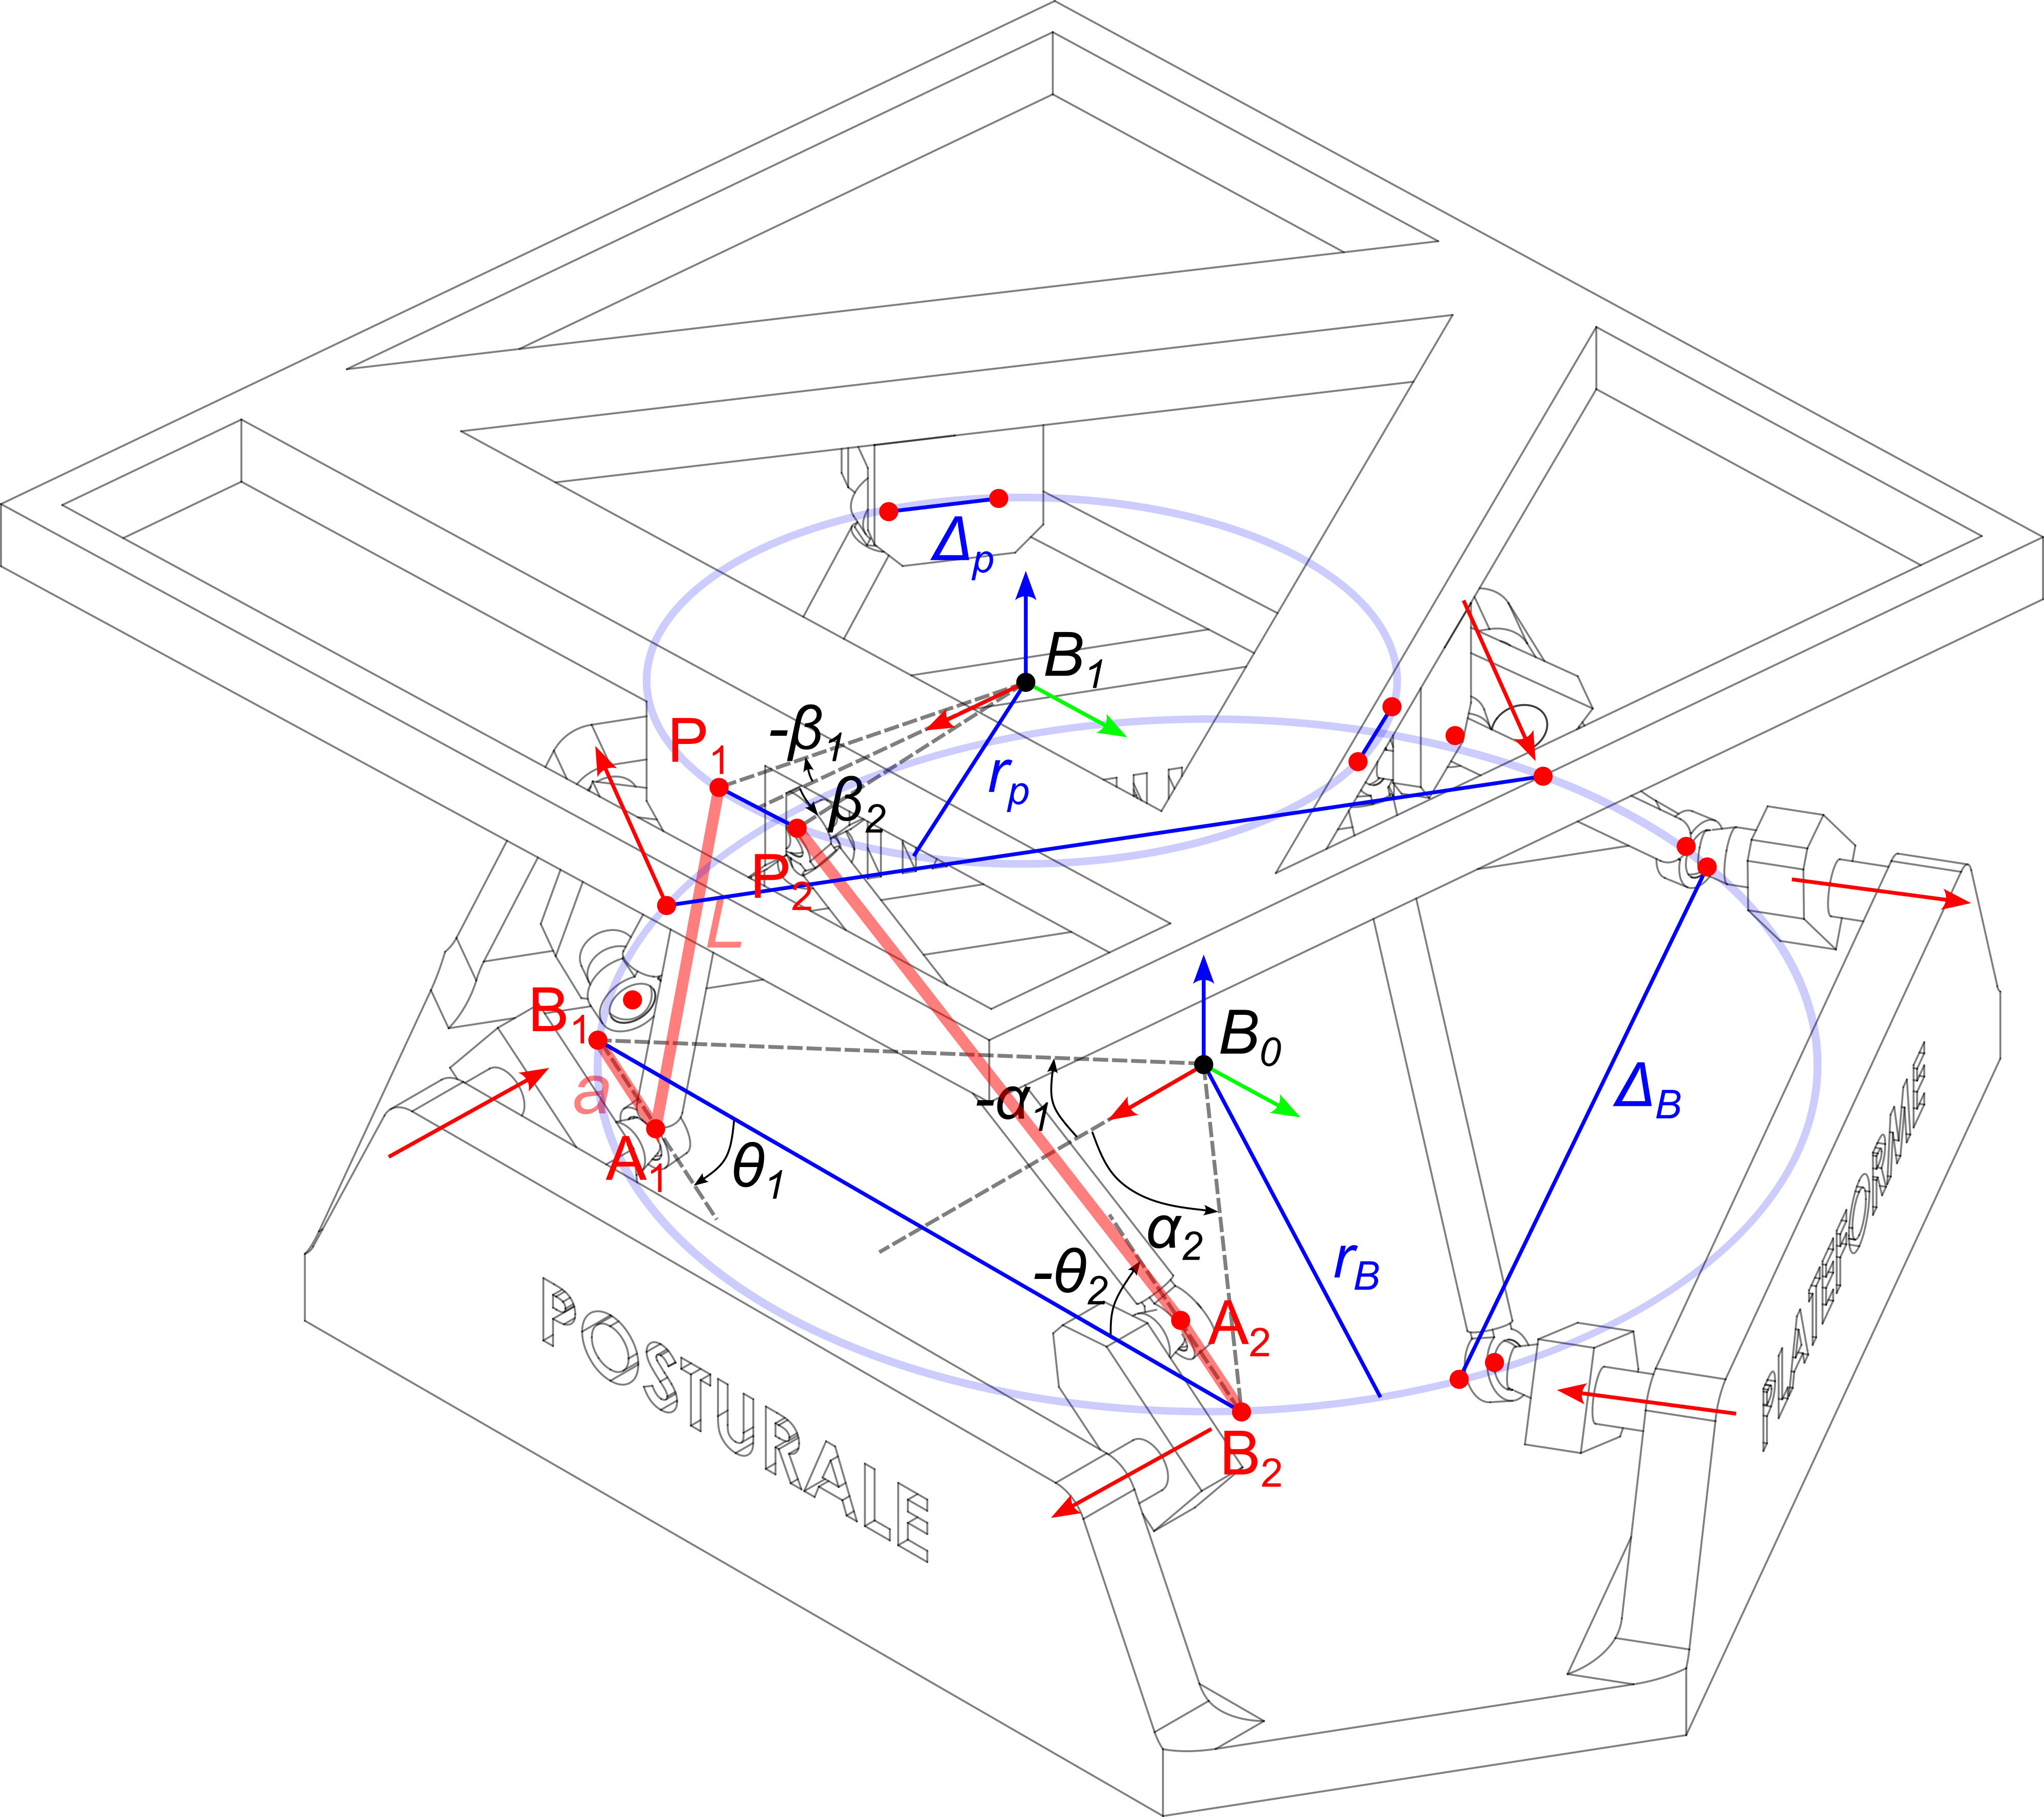
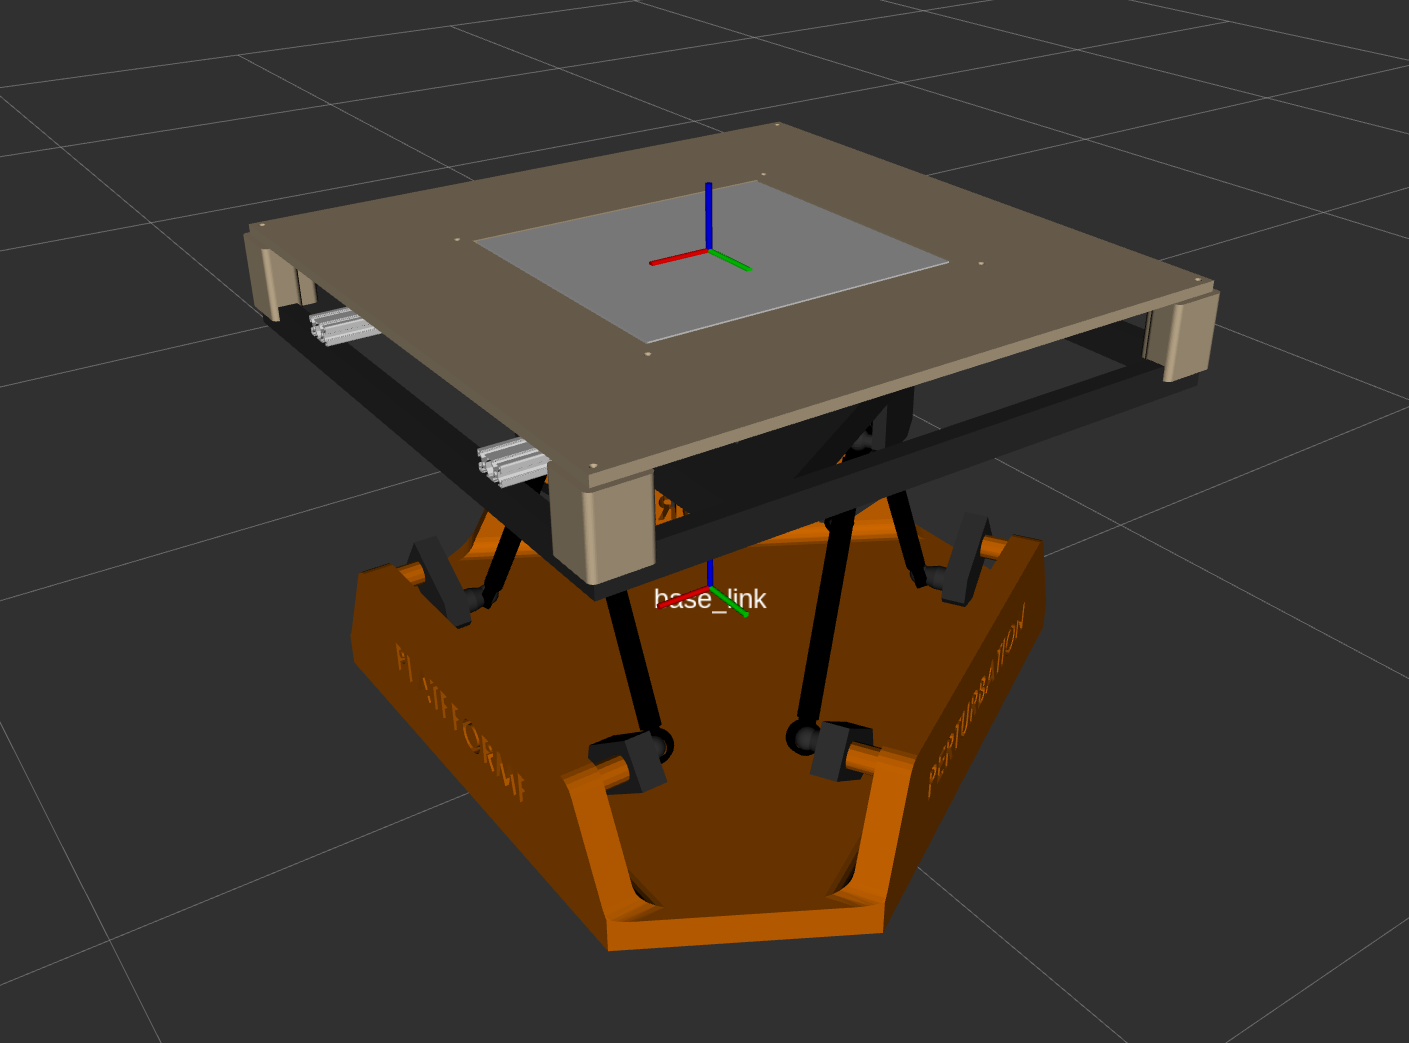
Engineering internship developing a ROS2 controller for a 6-DOF RSS6 robotic platform. Integrated CANopen communication for actuator control, implemented forward and inverse kinematics models, and used motion capture to quantify positioning accuracy.

Aquabot — Autonomous Surface Vehicle
Challenge Sep – Dec 2024 · École Centrale de Nantes

Aquabot — Autonomous Surface Vehicle

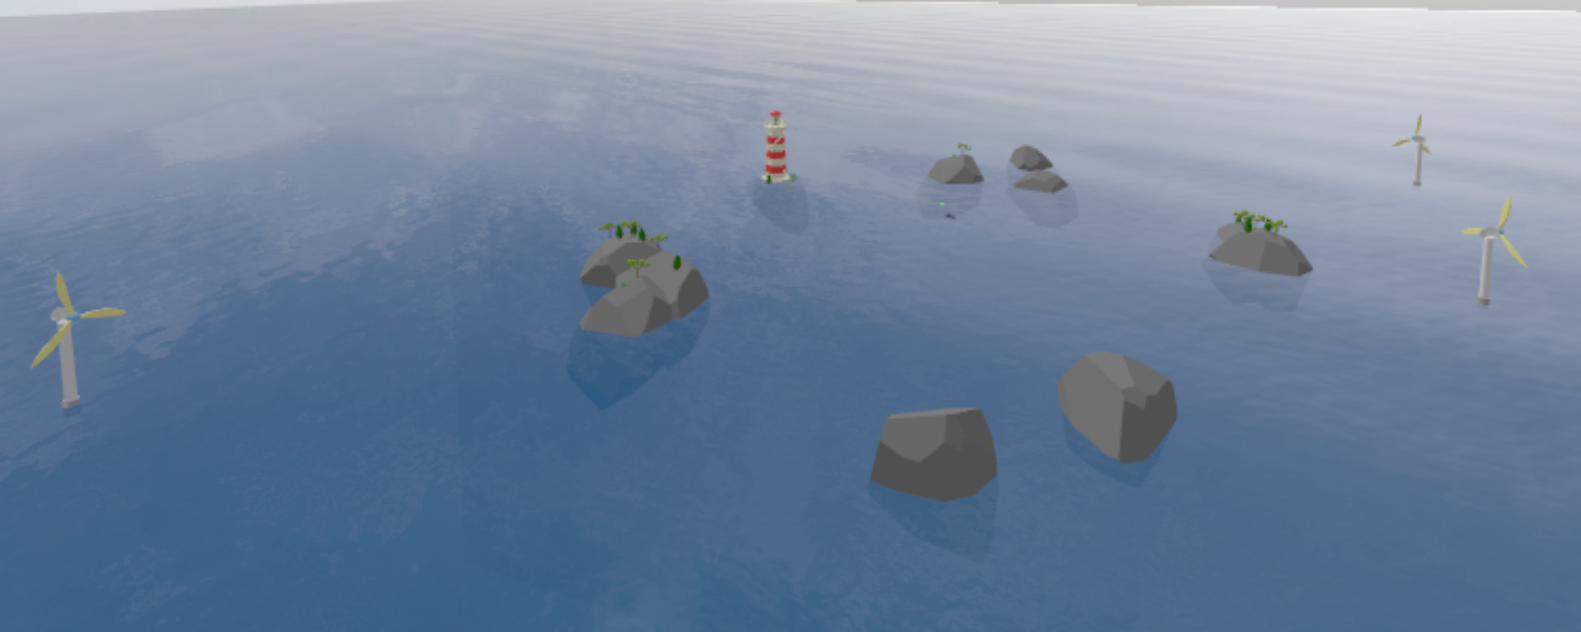
Led a team of 5 in the Aquabot 2024 autonomous boat challenge with Naval Group. Programmed ROS2 nodes for GPS waypoint navigation and reactive control to handle swell and wind disturbances on an autonomous surface vehicle.

LeRobot — RL on a Robotic Arm
Hackathon Jun 2024 · HuggingFace

LeRobot — RL on a Robotic Arm

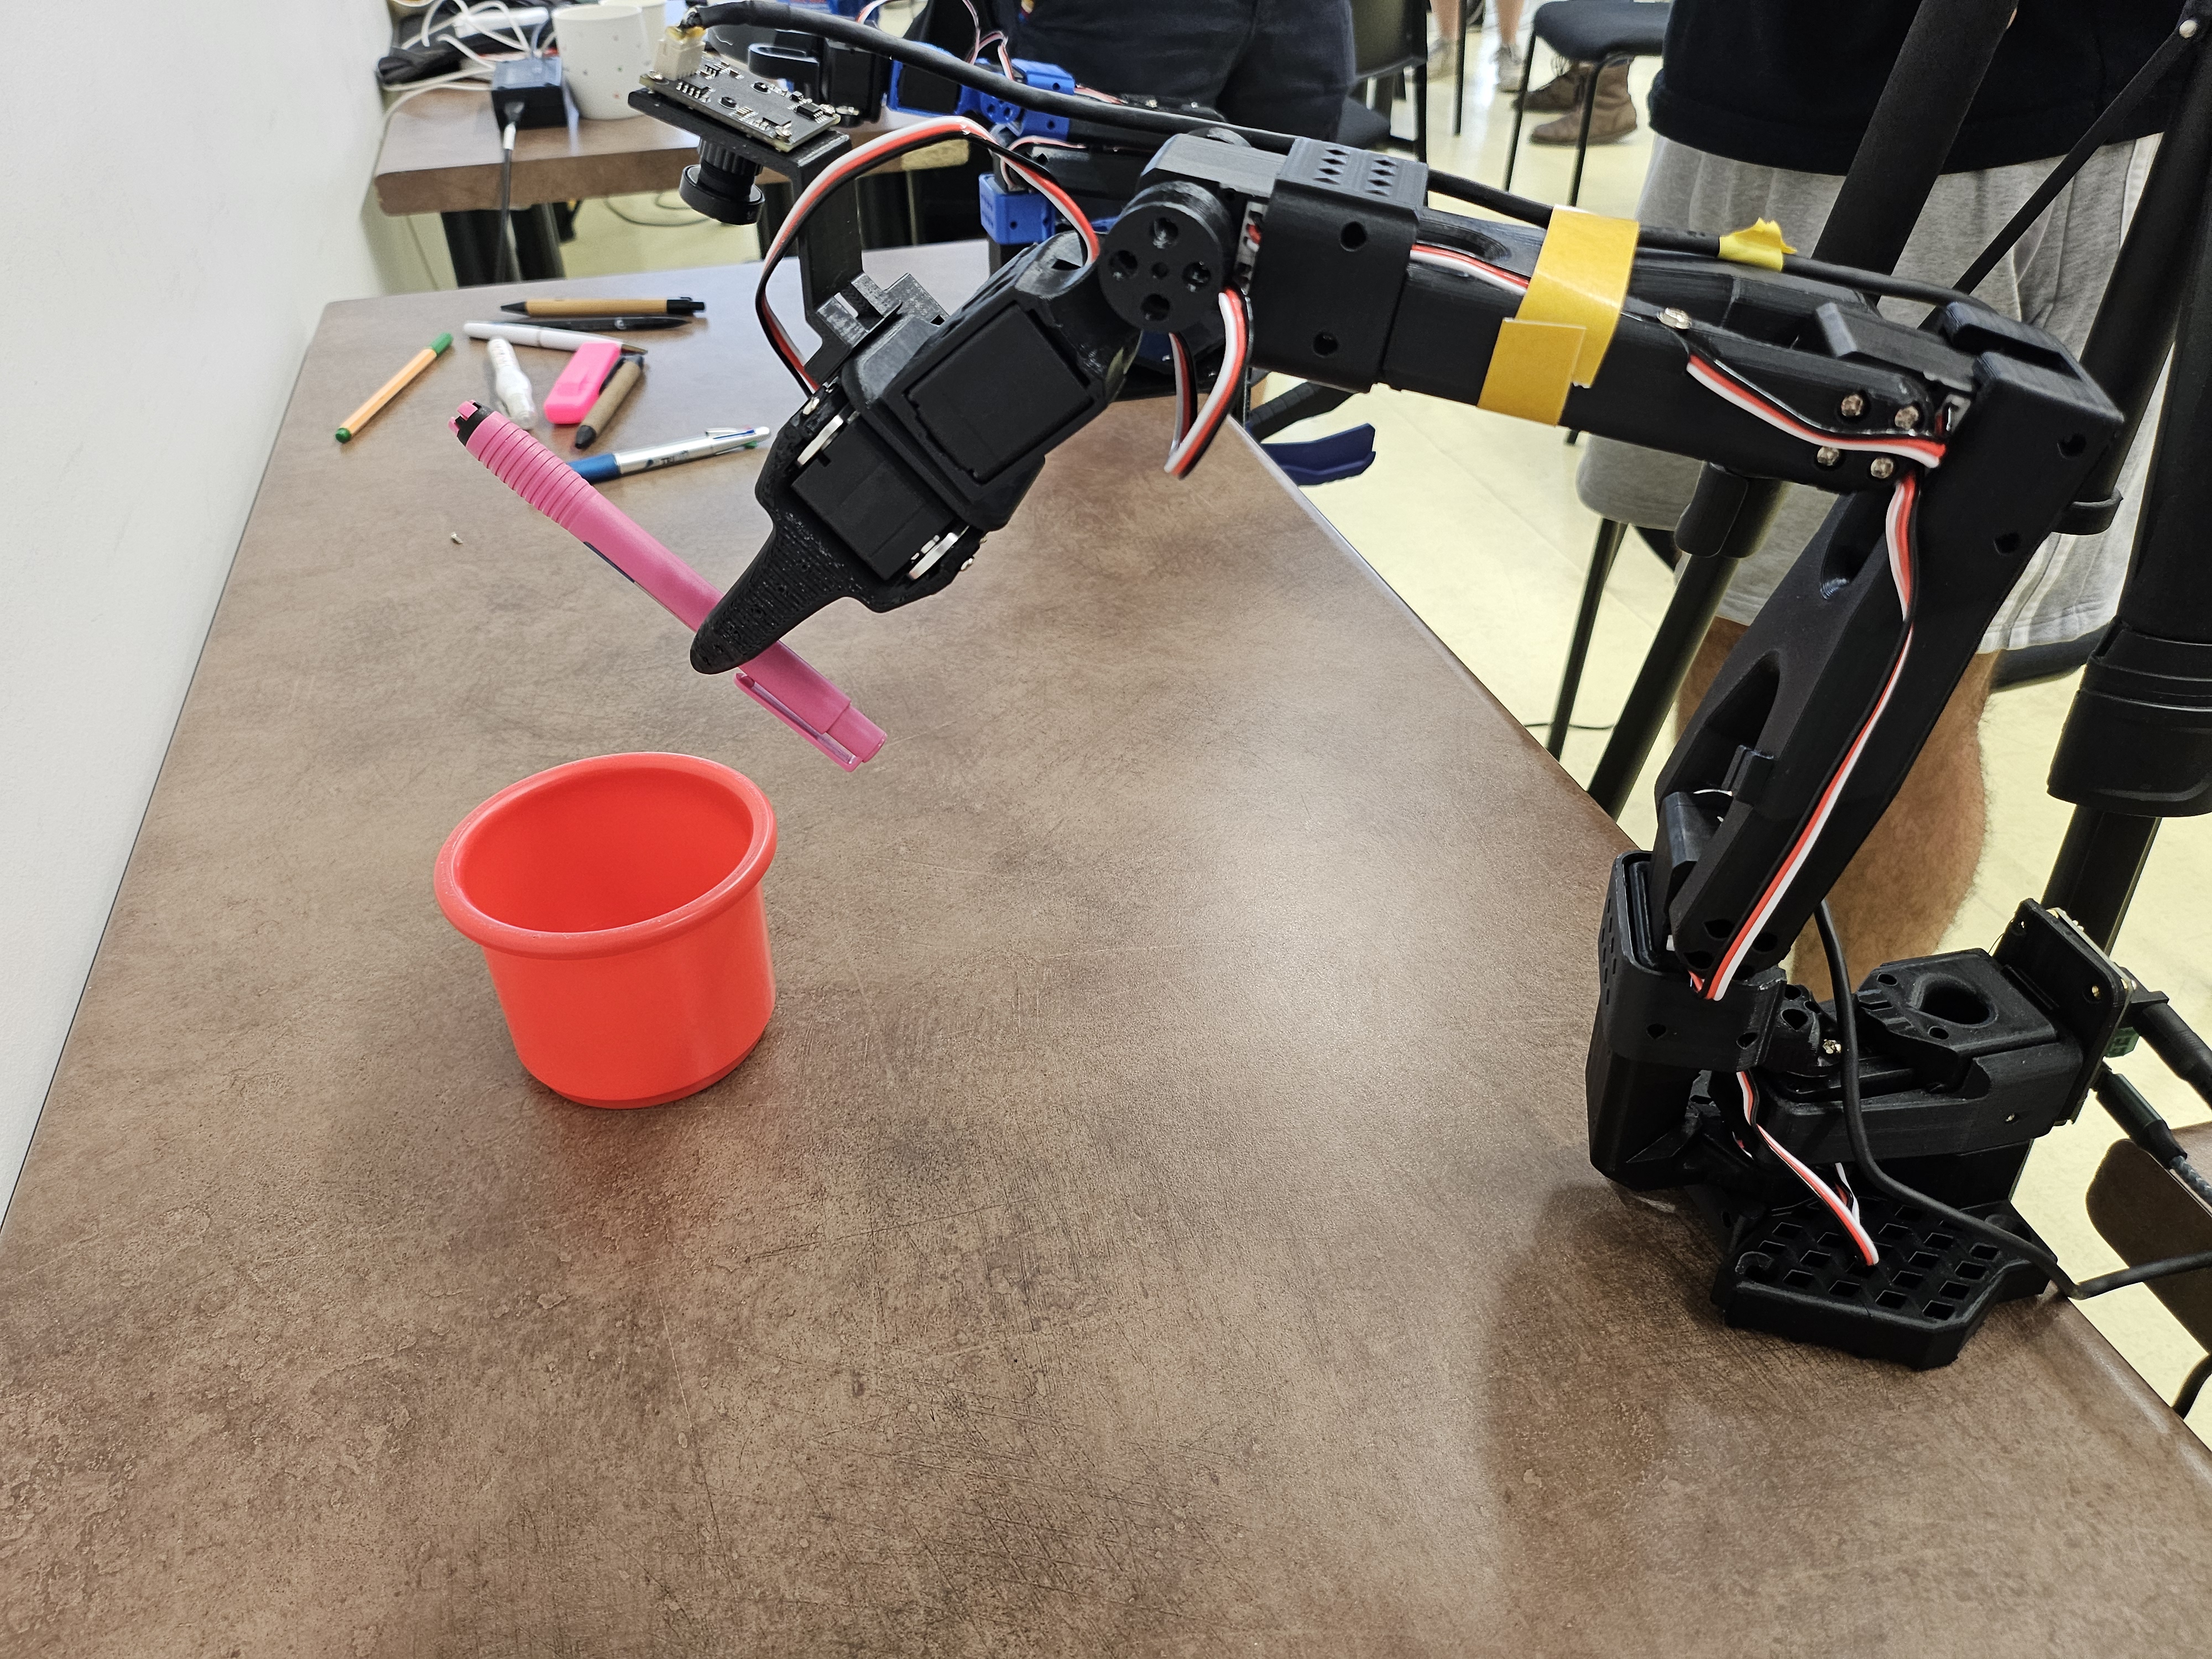
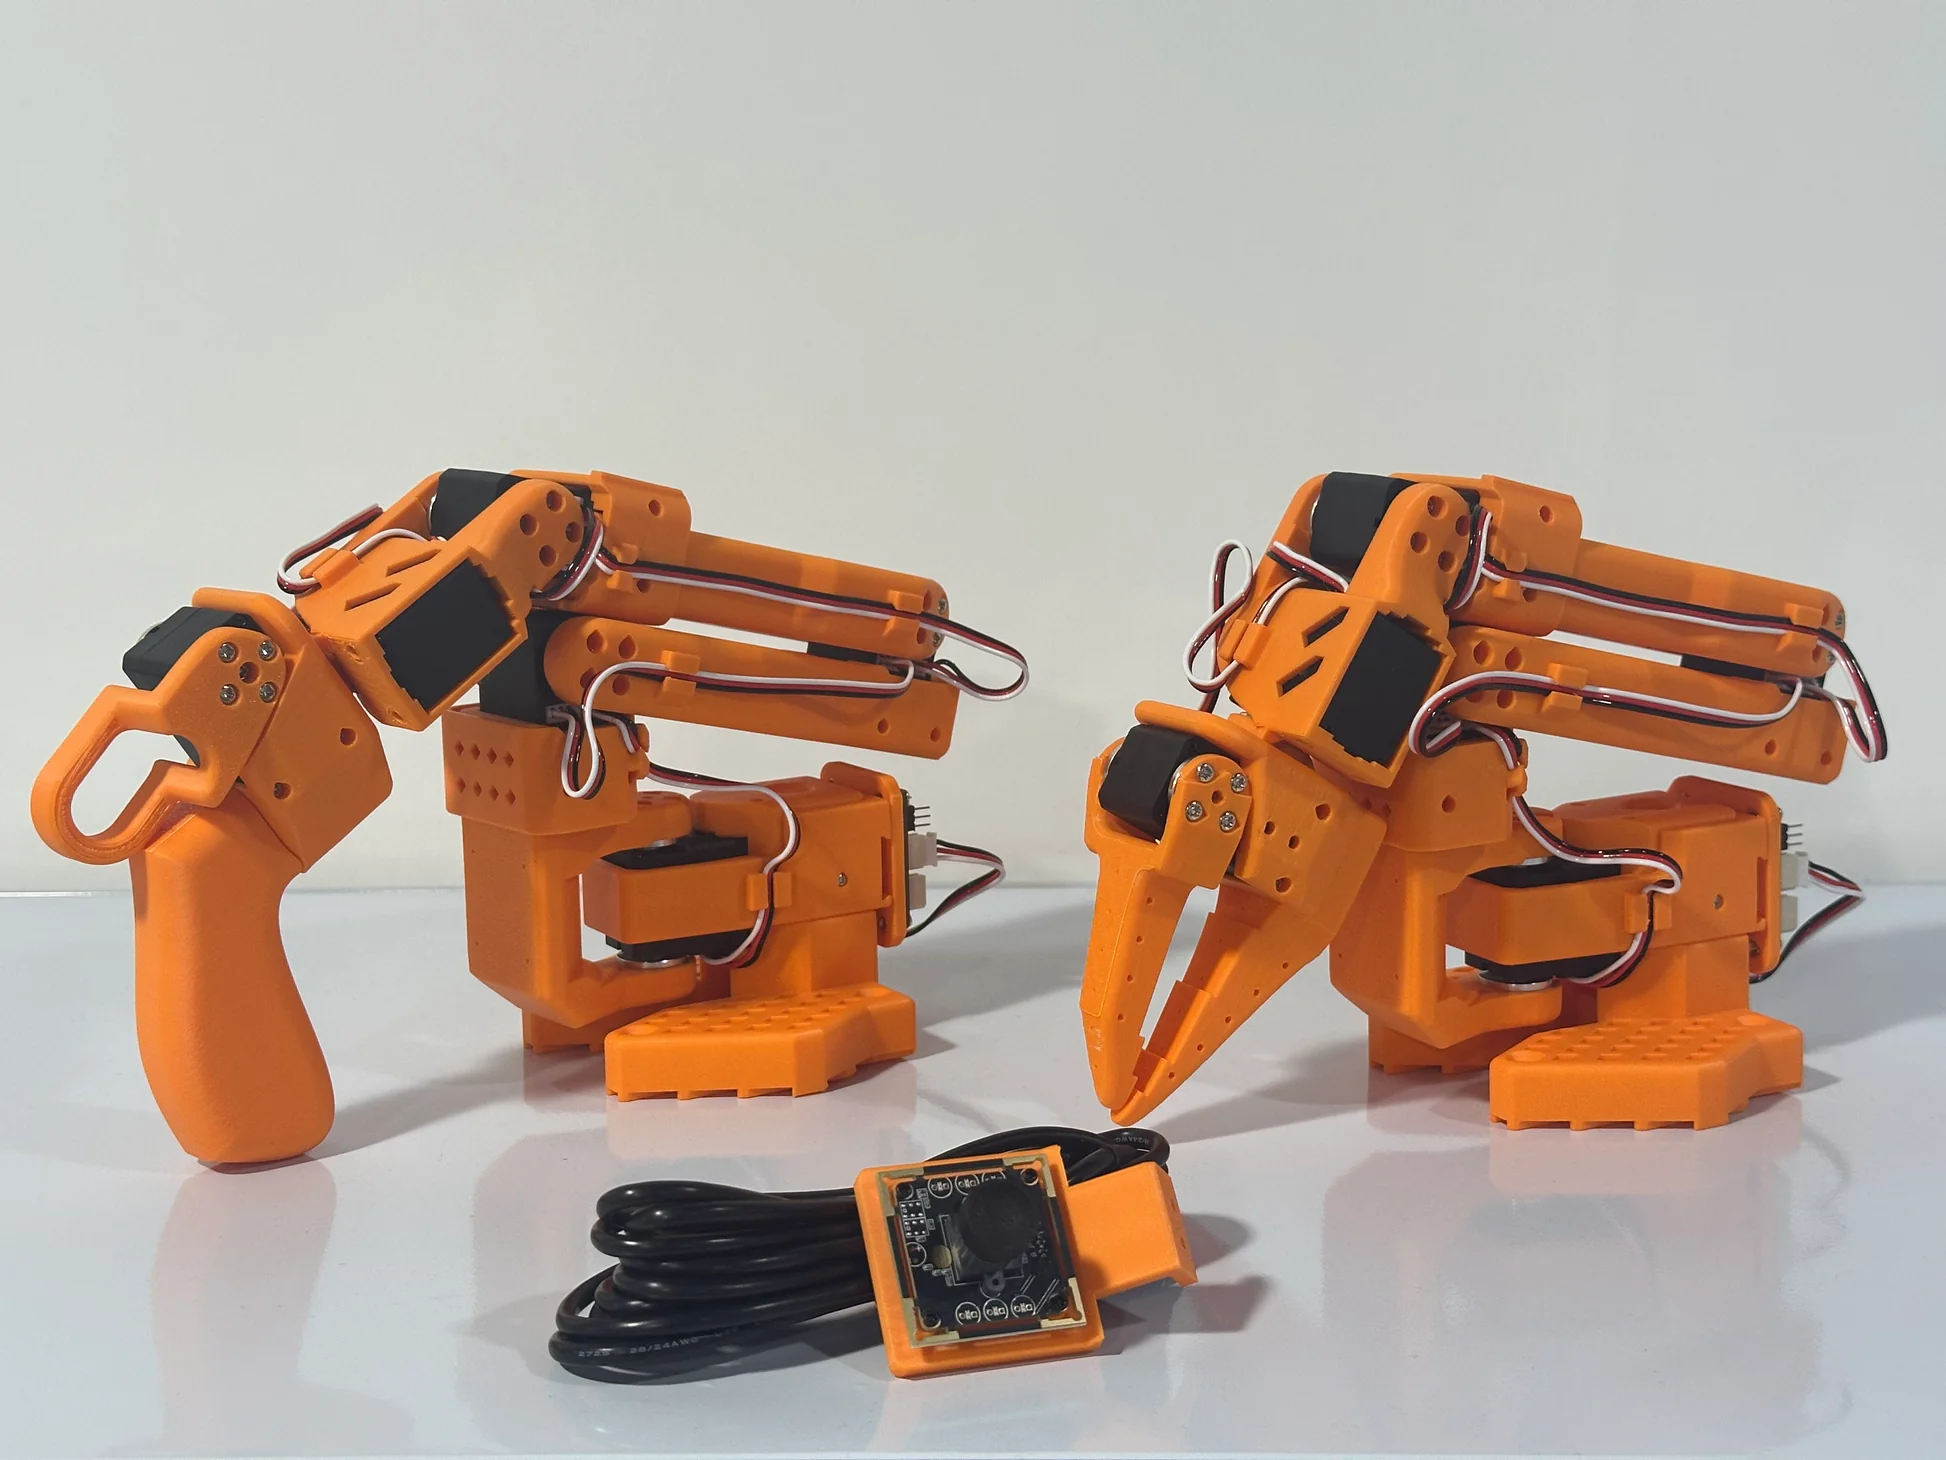
Hugging Face LeRobot hackathon: trained a reinforcement learning policy for manipulation on a low-cost robotic arm. Explored reward shaping and domain randomization techniques to achieve reliable task completion.

Bicycle Anti-Lock Braking System
Project Sep 2023 – Jan 2024 · Lycée Chaptal

Bicycle Anti-Lock Braking System

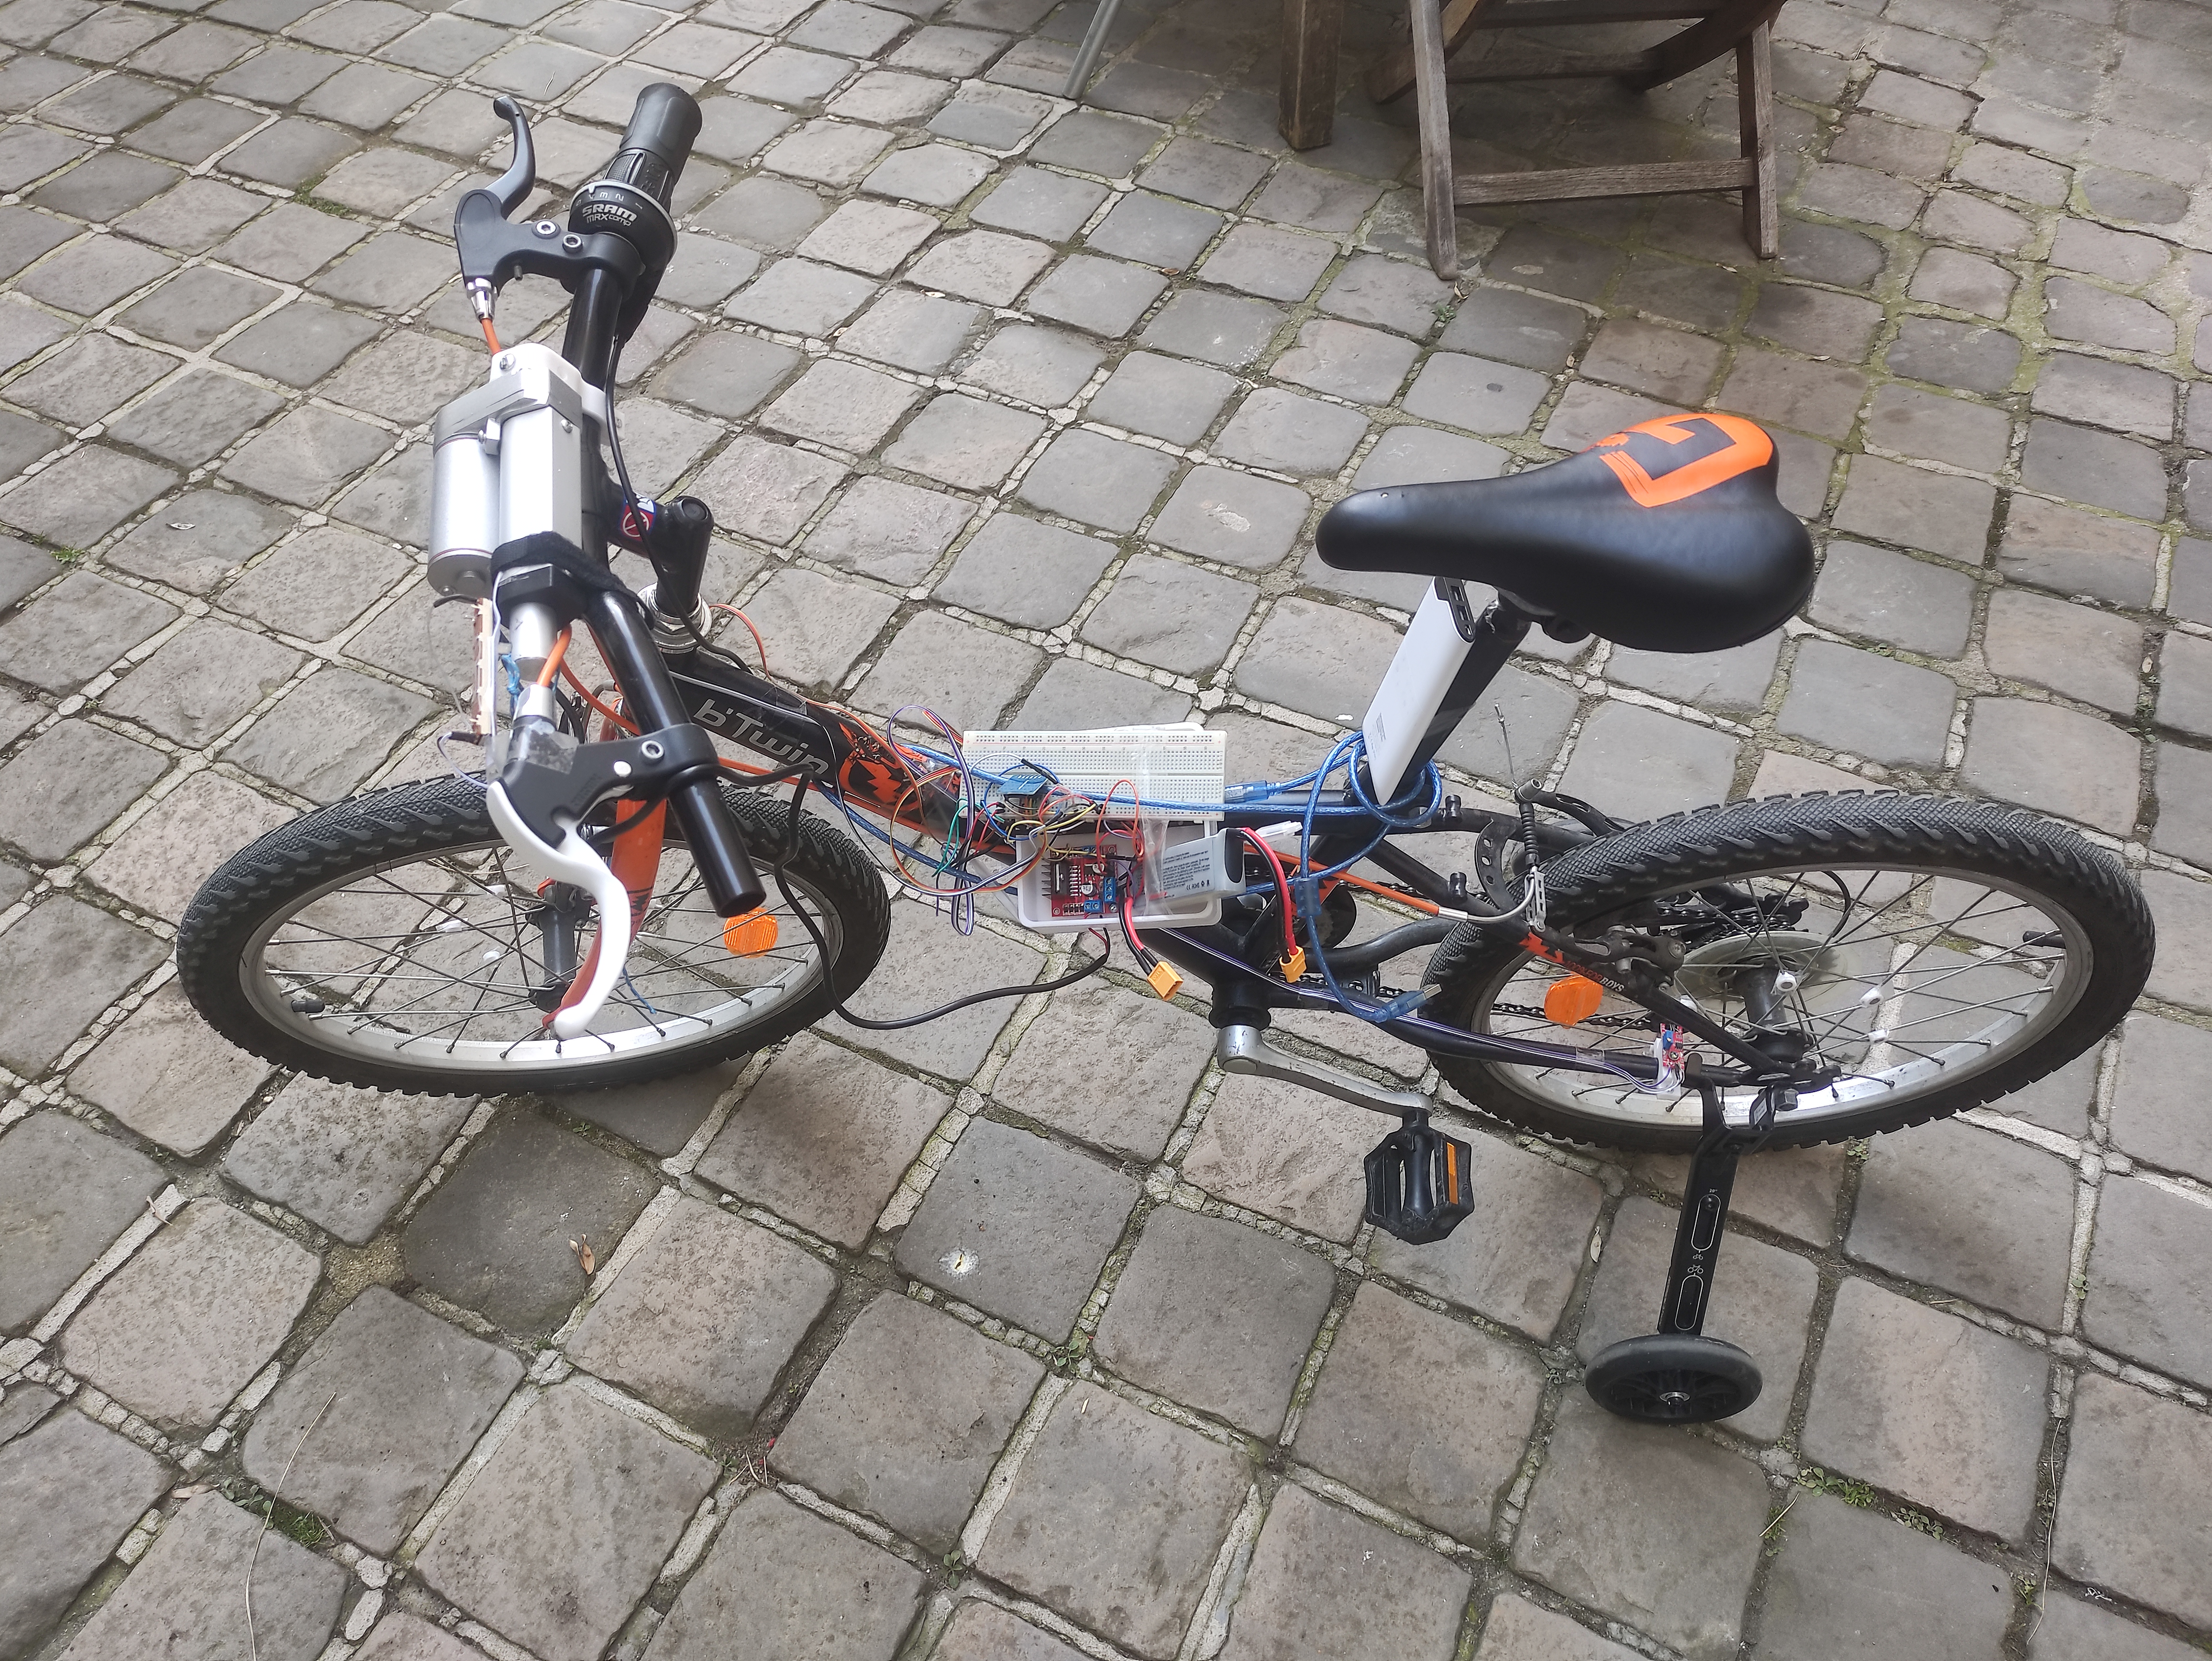
Conducted a feasibility study of an ABS system applied to bicycles and built a working prototype using an Arduino and 3D-printed parts. Collaborated with a senior e-VTT engineer from Décathlon to validate the design and mechanical choices.

Mathis Group – EPFL

Semester Project

Feb 2026 - Jun 2026

Research laboratory of EPFL specialising in computational neuroscience and machine learning. Trained an RL agent to play table tennis using complex musculoskeletal models within the MyoSuite and MuJoCo frameworks. Implemented and built upon research paper methodologies to achieve SOTA performance. Transitioned the implementation to MuJoCo Warp, enabling parallel simulation on GPU using the mjlab framework.

EPFL AI Team

RL Engineer, PAWS Project

Feb 2026 - Jun 2026

Developed quadruped locomotion policies with reinforcement learning using NVIDIA Isaac Lab. Worked on sim-to-sim and sim-to-real transfer to deploy the learned policy on the Unitree Go2 quadruped robot.

Institute of Intelligent Systems and Robotics (ISIR)

Research Intern

Apr 2025 - Aug 2025

Research laboratory of Sorbonne University / CNRS specialising in robot learning and human-robot interaction. Developed IGM/DGM geometric models for a parallel robot and validated them against physical measurements. Designed a GUI for trajectory planning and execution. Implemented ROS2 low-level motor control over CAN bus, and integrated the robot with a motion capture system for closed-loop position feedback.

Omni

Intern

Jun 2024 - Jul 2024

Start-up dedicated to the mobility of disabled people using electric devices. Prepared, repaired, and reconditioned electric scooters. Created educational and technical videos for customers and technicians.

EPFL

MSc - Robotics (Double Degree)

2025 - present

Specializing in the intersection of Reinforcement Learning and autonomous systems. Focusing on Robot Dynamics, Control Systems, and Deep Learning. Relevant courses: Legged robots, Reinforcement learning, Machine learning I, Model predictive control, Advanced control systems, Applied data analysis, Deep learning.

École Centrale de Nantes

MSc - Engineering

2023 - 2025

Engineering student at a highly selective French Grande École conferring a degree equivalent to a Master of Science. Specialization in Robotics, Control Systems, and Software Engineering.

Lycée Chaptal

Classes Préparatoires aux Grandes Écoles (MPSI/MP)

2021 - 2023

Two-year intensive undergraduate program in Mathematics and Physics preparing for competitive national entrance exams to the Grandes Écoles.

Lycée Carnot

Baccalauréat (Maths-Physics) with Honours

Sep 2018 - Jun 2021

Equivalent to a High School Diploma, majoring in Mathematics and Physics, obtained with Honours.